Handheld Manipulation Data Capture
UMI
Handheld Manipulation · Data Capture
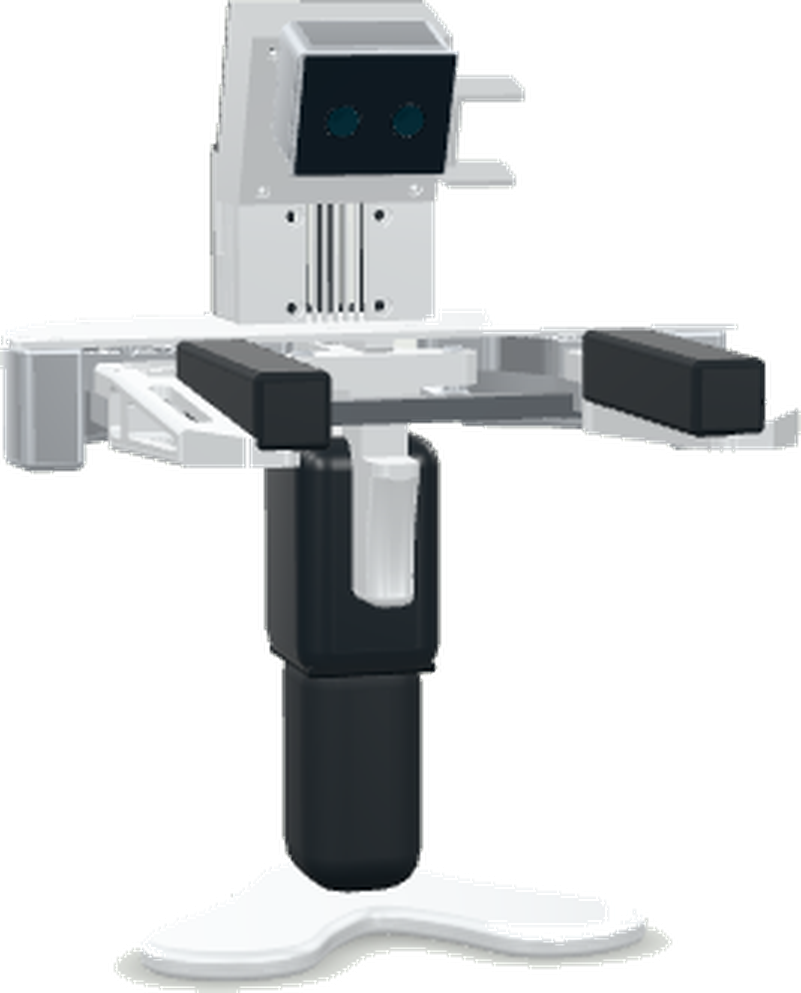
A handheld data capture device for real-world grasping, placing and assembly tasks, with support for joint capture alongside the EGO first-person system.
A first-person, multimodal data-capture device for embodied-AI training. Four global-shutter cameras, IMU, and audio are hardware-synchronized to capture real operations in full, providing a reliable foundation for high-quality robot data collection.
Core Features
Product Specifications
Basic Information
Weight650 g
PowerExternal power supply
Capture ModeHandheld, joint capture with the EGO first-person system
Data SyncStandalone hardware sync; multi-device software sync error ≤3ms
Data DeliveryVideo, point cloud, IMU data, gripper opening data, timestamps and calibration filesPost-processed trajectory delivery supported
Gripper
Maximum Gripping Force8 kg
Maximum Opening100 mm
Vision
ImagingGlobal shutter, color and infrared image capture
Image Modes1280×720 @30fps / 848×480 @90fps, depending on delivery configuration
Field of ViewNominal approx. 87°×58°, subject to actual calibration
Reference Depth Range0.07 – 0.50 m, closest range varies with capture mode
Inertial
IMU Type6-axis
IMU Sampling Rate400 Hz
Pose & Software
Pose OutputPost-processed 6DoF position and orientation trajectory
Positioning AccuracyStandalone ≤5mm, EGO + UMI fusion ≤3mm
SoftwareCapture, calibration, real-time monitoring, playback and export, with SDK
Ready to Start with UMI on Robot AI?
Contact us now to get exclusive solutions and preferential quotes
Contact Us